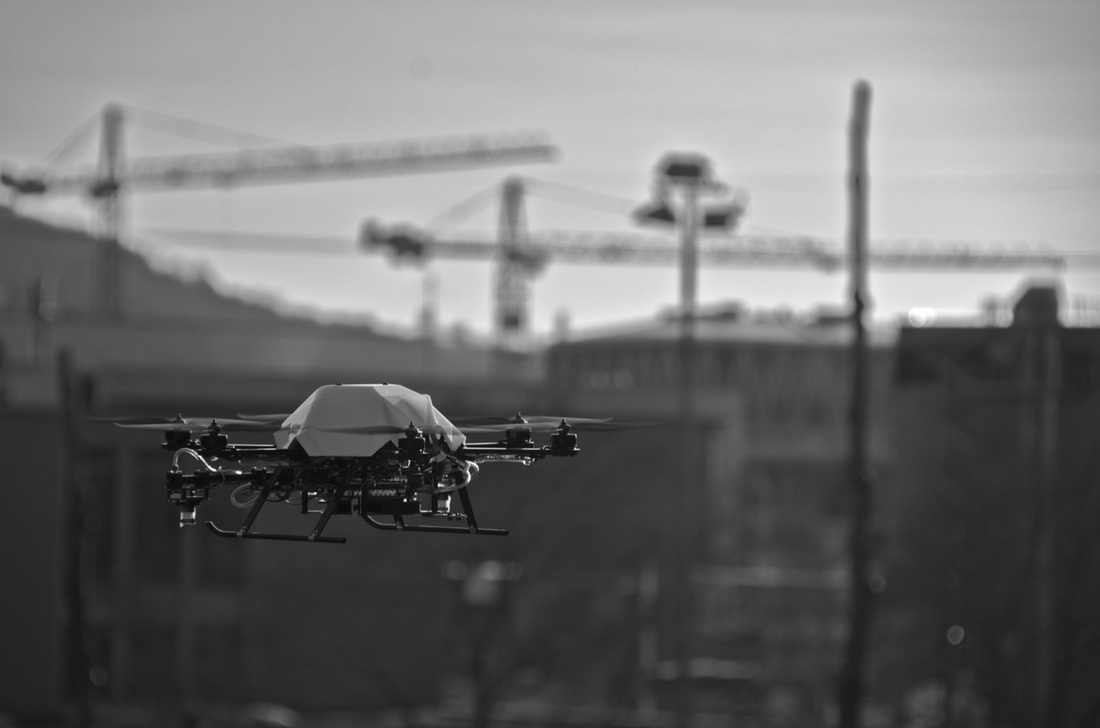
Reference sample. This example uses material from Dr. Kostas Alexis's website archive to demonstrate this section.
Autonomous aerial robots combine perception, localization, planning and control to move through unfamiliar environments. The reference research explores how a robot can choose useful viewpoints while accounting for uncertainty in its estimated position.
Research themes
- Exploration and mapping of unknown spaces.
- Coverage planning for structural inspection.
- Receding-horizon planning and uncertainty-aware navigation.
The original research page includes experimental demonstrations, publications, software and datasets.
Source: Kostas Alexis reference website.